
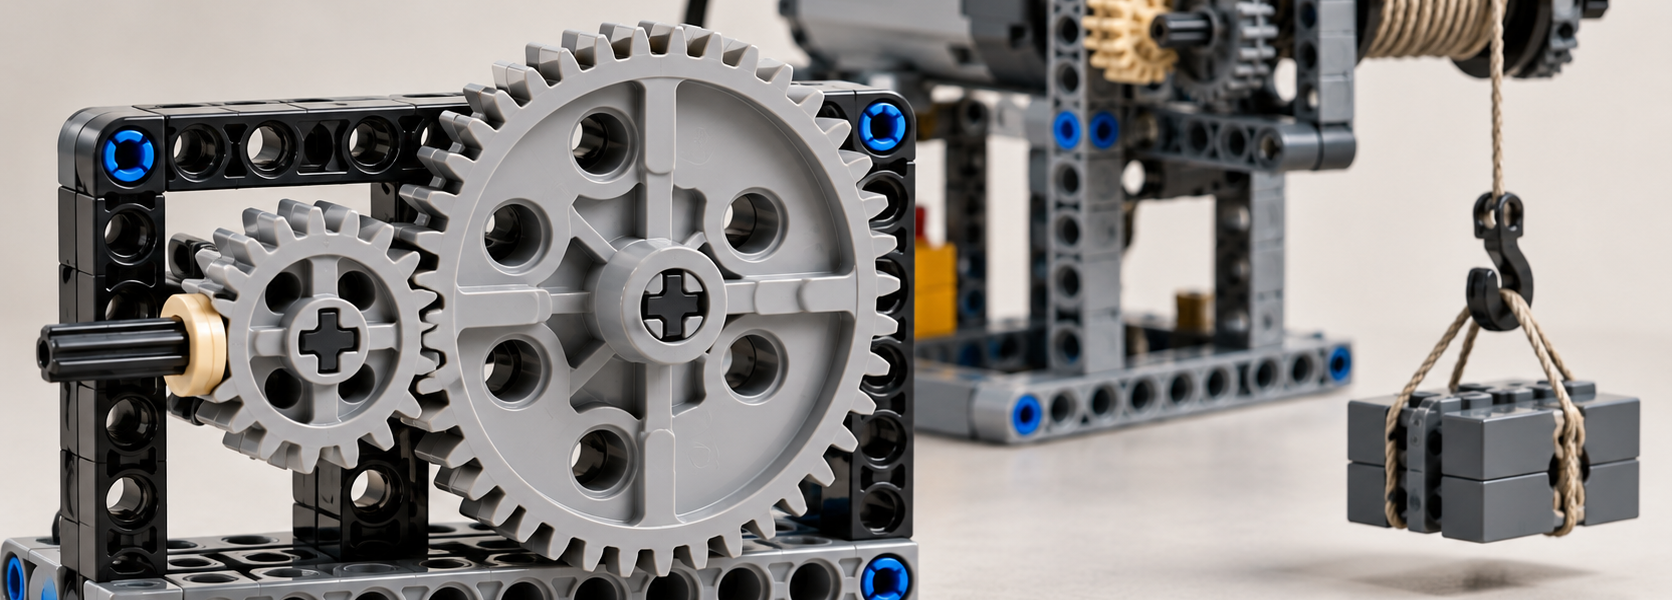

A LEGO Technic MOC can have a perfectly good motor and still perform badly. A fast-looking off-road truck may struggle to start, while a winch spins enthusiastically until you ask it to pull something. Both problems invite the same design question: are you using the motor’s available speed and torque in the right proportions?
Gears let builders make that choice. They do not create extra power; they trade rotational speed for turning torque, or the other way around. This guide approaches the subject from the job your mechanism needs to do. We’ll calculate a few ratios, examine how the gears must actually be connected, and explain why a design that is correct on paper can still bind, slip or stall. The worked examples are calculations and proposed experiments, not measurements from a physically tested model.
Start with the load, not with a pile of gears
Imagine three projects. A lightweight display car needs its wheels to turn at a lively rate. A winch must turn a cable drum slowly against resistance. A crane needs controlled movement and dependable support for its arm. Using the same motor in each project does not mean using the same gear train.
Speed tells you how many revolutions a shaft makes in a given time, often expressed in revolutions per minute (rpm). Torque is turning effort: the tendency of that shaft to rotate a load around its axis. The two quantities are related through mechanical power. An ideal gearbox that doubles output speed must reduce output torque accordingly, and a reduction gearbox increases available output torque by sacrificing speed. LEGO Education explains this tradeoff in its Gear lesson.
A useful first question is therefore not ‘Which combination gives the biggest ratio?’ but ‘What must the output shaft actually do?’ Then choose a manageable starting ratio and test it in the specific construction.
Driver and driven gear: the 8-tooth/24-tooth example
The driver is attached to the input, such as a hand crank or motor. The driven gear (also called the follower) receives the motion. Consider a common arrangement with an 8-tooth driver meshing with a 24-tooth driven gear. The small wheel must turn three times for the big wheel to turn once: 24 ÷ 8 = 3. This is a 3:1 reduction.
Now reverse their roles. If the 24-tooth wheel drives the 8-tooth wheel, one revolution of the large wheel produces three revolutions of the small one. That is a 1:3 ratio, or a threefold speed increase. Both gears must mesh and be supported correctly; these are not interchangeable suggestions for every possible gear variant.
Throughout this article, we use one consistent convention:
i = teeth on the driven gear ÷ teeth on the driver gear.
An i greater than 1 is a reduction. An i smaller than 1 increases speed. The theoretical output speed is the input speed divided by i. Some resources write the speed ratio in the opposite order, so check each author’s labels before comparing numbers. LEGO Education’s Simple Machines gear exercises offer an accessible introduction to drivers, followers and direction.
Four ratios calculated from the same input
Suppose the input shaft is turning at a steady 90 rpm. This is an illustrative, fixed input speed, not a claim about a particular LEGO motor. We obtain the following kinematic results:
| Gear arrangement | Overall ratio (i) | Calculated output at 90 rpm input |
|---|---|---|
| 8-tooth driver → 24-tooth follower | 3:1 reduction | 30 rpm |
| 24-tooth driver → 8-tooth follower | 1:3 speed increase | 270 rpm |
| Two separate 8→24 reduction stages | 9:1 reduction | 10 rpm |
| Single-start worm → 24-tooth wheel | 24:1 reduction | 3.75 rpm |
At the same input torque and in a perfectly efficient gearbox, a 3:1 reduction would provide three times the output torque, while 9:1 would provide nine times. Real gears have friction and deformation losses, so actual output torque is lower. Crucially, friction does not alter the tooth-count ratio. Under load, however, a real motor may turn more slowly than the 90 rpm assumed here, and the output slows with it. These figures should never be presented as observed speeds or lifting capacities.
How to build a real 9:1 compound reduction
For a winch, a single 3:1 reduction may not be enough. A useful next experiment is to combine two 3:1 stages: 3 × 3 = 9:1. The geometry of the shafts is essential, not just the number of gears.
- Put an 8-tooth input gear on the first shaft and mesh it with a 24-tooth gear on a second shaft.
- On that same second shaft, fasten another 8-tooth gear so both intermediate gears must rotate together.
- Mesh the second 8-tooth gear with another 24-tooth gear on the output shaft.
- Support all three shafts on a rigid frame. Rotate the input by hand and count output revolutions before attaching a motor.
The first stage reduces 90 rpm to 30 rpm; the second reduces 30 rpm to 10 rpm. Merely arranging four gears in a line is not equivalent. In a straight chain of ordinary meshing gears, intermediate gears can cancel out of the overall speed ratio. LEGO Education calls the mechanically connected arrangement compound gearing, and Sariel’s Gears Tutorial explains how to multiply ratios of successive driver/follower pairs.
What an idler gear changes—and what it does not
Try the sequence 24 → 8 → 24, with all three gears free to turn on separate shafts. The middle 8-tooth wheel is an idler. The first 24-tooth wheel and last 24-tooth wheel rotate at the same speed: the overall ratio is 1:1. The idler’s number of teeth cancels when calculating the end-to-end ratio.
Direction does change. Two directly meshing external gears rotate in opposite directions. With an idler between the first and last gear, the output turns in the same direction as the input. That is also demonstrated in LEGO Education’s idler model. The extra mesh still adds friction, moving parts and some backlash, even though it does not multiply torque.
Worm gearing: compact reductions with important tradeoffs
A worm gear resembles a short screw engaging a toothed wheel. With a single-start worm, one full turn advances the follower by one tooth. Driving a 24-tooth gear therefore produces a theoretical 24:1 reduction: at 90 rpm input, the follower turns at 3.75 rpm. Sariel discusses this calculation, the worm’s applications and its practical limits in his gear guide.
That makes a worm attractive for compact winches, lifting mechanisms and slow positioning systems. Some worm arrangements strongly resist being turned backwards by the load, but do not assume that every worm gearbox is a fail-safe brake. Back-driving behavior depends on the particular design, friction, gear geometry and load. Never rely on an untested toy-brick mechanism to suspend anything that could cause injury or damage.
There are additional engineering costs. A worm can produce significant sliding friction and tends to exert a force along its own shaft. The assembly needs firm axial support to prevent the worm moving away from the follower. A mathematically impressive reduction will not help if the worm shifts out of position under load.
Choosing a ratio for three MOC projects
A powered vehicle: do the wheels need more speed or more torque?
Start with a modest reduction rather than blindly gearing up. If the vehicle accelerates easily and the motor has capacity left under the intended load, trying a faster ratio may increase road speed. If the model struggles to start, stalls against an obstacle or slows dramatically on carpet, increasing wheel speed through the gears can make matters worse. A reduction may help the motor operate at a more useful speed while the wheels receive greater turning torque.
When comparing ratios, keep the surface, tires, battery condition and vehicle mass as consistent as possible. A motor’s operating speed changes with load, so calculated gear ratios by themselves are not vehicle speed predictions.
A winch: slow motion and drum radius matter
A reduction such as 3:1 can be a sensible first trial, with 9:1 or an appropriately braced worm considered if controlled motion and greater torque are needed. The drum still determines how that torque translates into pulling force. In a simplified ideal model, the line tension equals drum torque divided by drum radius. A larger drum requires more torque to produce the same pull.
This is why ‘9:1’ is not an answer to ‘How much weight can it lift?’ You also need to know motor torque at the operating point, gearbox efficiency, drum geometry, support stiffness and the strength of the relevant pieces. We have not measured these values or tested a winch for this article.
A crane or lifting arm: avoid designing only for motion
For a slow lift, a large reduction can make movement easier to control, but the load can bend axles, deform supports or force poorly secured gears apart. Think about the arm’s leverage, the connection points and what happens when the motor stops. A clutch or mechanical stop may be appropriate depending on the mechanism, but its suitability needs to be established for that particular build. The gearbox is only one part of a safe, reliable model.
Why good calculations fail in real LEGO Technic builds
Axle support: Ideally, brace loaded shafts at appropriate points in a rigid Technic structure. An axle that bends or can slide sideways can allow teeth to skip. Support the output as carefully as the input; the highest torque is often found near the slow end of the gear train.
Small gears: The 8-tooth wheel is useful for compact high-ratio reductions, but Sariel notes that small gears can be vulnerable under high torque. Do not assume that a tiny gear placed at the most heavily loaded stage will survive simply because the mathematics works. Gear versions and reinforcing geometry may differ.
Axle spacing: For the usual compatible spur gears, the approximate pitch-center spacing measured in studs is (teeth of first gear + teeth of second gear) ÷ 16. An 8-tooth and a 24-tooth wheel therefore require two studs between shaft centers. This relation is explained by Technic Brick Power; the exact physical mounting still depends on the gear variant and geometry. Do not force gears into positions that bind.
Backlash: There must be some play between meshing teeth. Too much causes delayed response after reversing the motor and makes positioning less precise; it can become especially noticeable in multi-stage trains. Sariel discusses this effect separately from transmission efficiency.
Friction and motor behavior: Additional meshes cost power. No single fixed efficiency percentage can be assumed for all LEGO gearboxes. Increasing reduction may let the motor handle a load more easily, but it cannot produce unlimited torque or protect a stalled motor from overheating.
A five-minute test before you power your gearbox
This is a suggested exercise, not a test we conducted. Build a supported 8-tooth/24-tooth pair. Mark the first and second shafts, rotate the 8-tooth wheel three full turns and check that the 24-tooth wheel makes one turn in the opposite direction. Then drive the large gear and observe the speed increase at the smaller one. If the mechanism catches or skips, fix the support or spacing before continuing.
For a second experiment, build the compound 9:1 train described above. With no motor or load attached, confirm that nine input turns give one output turn. That simple hand check catches an incorrectly assembled compound gearbox before it becomes buried inside a MOC.
Use Sariel’s calculator without confusing the result with a performance test
The LEGO Gear Ratio Calculator by Sariel lets builders select driver and follower gears, add further pairs and calculate an overall ratio. Try 8→24, then add a second 8→24 stage. You should obtain 9:1 for the two-stage reduction. Compare the tool’s input/output labelling with the convention used in your own notes.
It is a valuable calculation aid, but cannot guarantee that shafts are sufficiently supported, parts can mesh in your exact frame, or the motor will maintain a specified input rpm under load. Treat it as a design check, followed by a careful physical build and test.
A useful decision checklist
- What must the output turn: wheels, cable drum, crane joint or something else?
- Do you need more speed or greater turning torque at that output?
- Which shaft is the input, which is the output, and how have you defined the ratio?
- Are your stages actually compound, with the intended gears fixed to the same intermediate shaft?
- Can each gear mesh at the correct spacing without rubbing nearby beams?
- Are loaded shafts and any worm gear braced against movement?
- Does the mechanism still turn freely by hand before a motor is attached?
- Have you checked the motor, supports and end stops under a suitably small test load?
The best gear ratio is the one your build can actually use
An 8-tooth driver turning a 24-tooth follower gives a straightforward 3:1 reduction. Two proper compound stages give 9:1. A single-start worm with a 24-tooth follower gives 24:1. Those are reliable calculations; they are not promises of real-world pulling power.
Choosing LEGO Technic gearing begins with the job the output shaft must perform and ends with a well-supported, tested assembly. Once that principle clicks, building a faster car or a more controlled winch becomes less about trial-and-error gear swapping—and much more about designing the mechanism for its purpose.
Sources and further reading
- LEGO Education — Simple Machines: Principle Models: Gears: drivers, followers, idlers, direction and compound gearing.
- LEGO Education — Gear (Simple & Powered Machines): speed/torque tradeoffs, gear-ratio calculations and worm gears.
- Sariel — Gears Tutorial: multi-stage ratios, worm gears, friction, gear variants and backlash.
- Sariel — LEGO Gear Ratio Calculator: multi-pair ratio calculations.
- Technic Brick Power — Gear Teeth and Pitch Radius: shaft-center spacing for conventional compatible gears.